Mobile manipulation in human-shared logistics

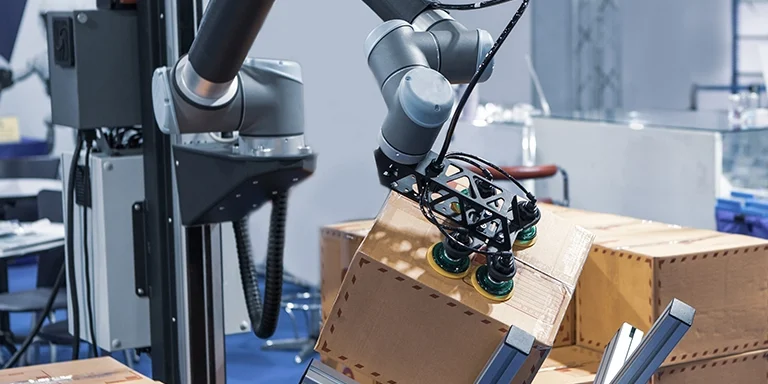
GRAIL optimizes warehouse operations by helping mobile robots adapt instantly to new products of varying shapes and sizes. By pairing visual information with dynamic task planning, it delivers highly flexible automation and safe human-robot collaboration in crowded logistics environments.

Sector:

Intralogistics

Industrial partner:

GRAIL use cases

Challenge

Logistics environments deal with a constant flow of different products, shapes and sizes. Today, robots often need CAD models or specific programming for each new item or workflow, making adaptation slow and costly.

GRAIL approach

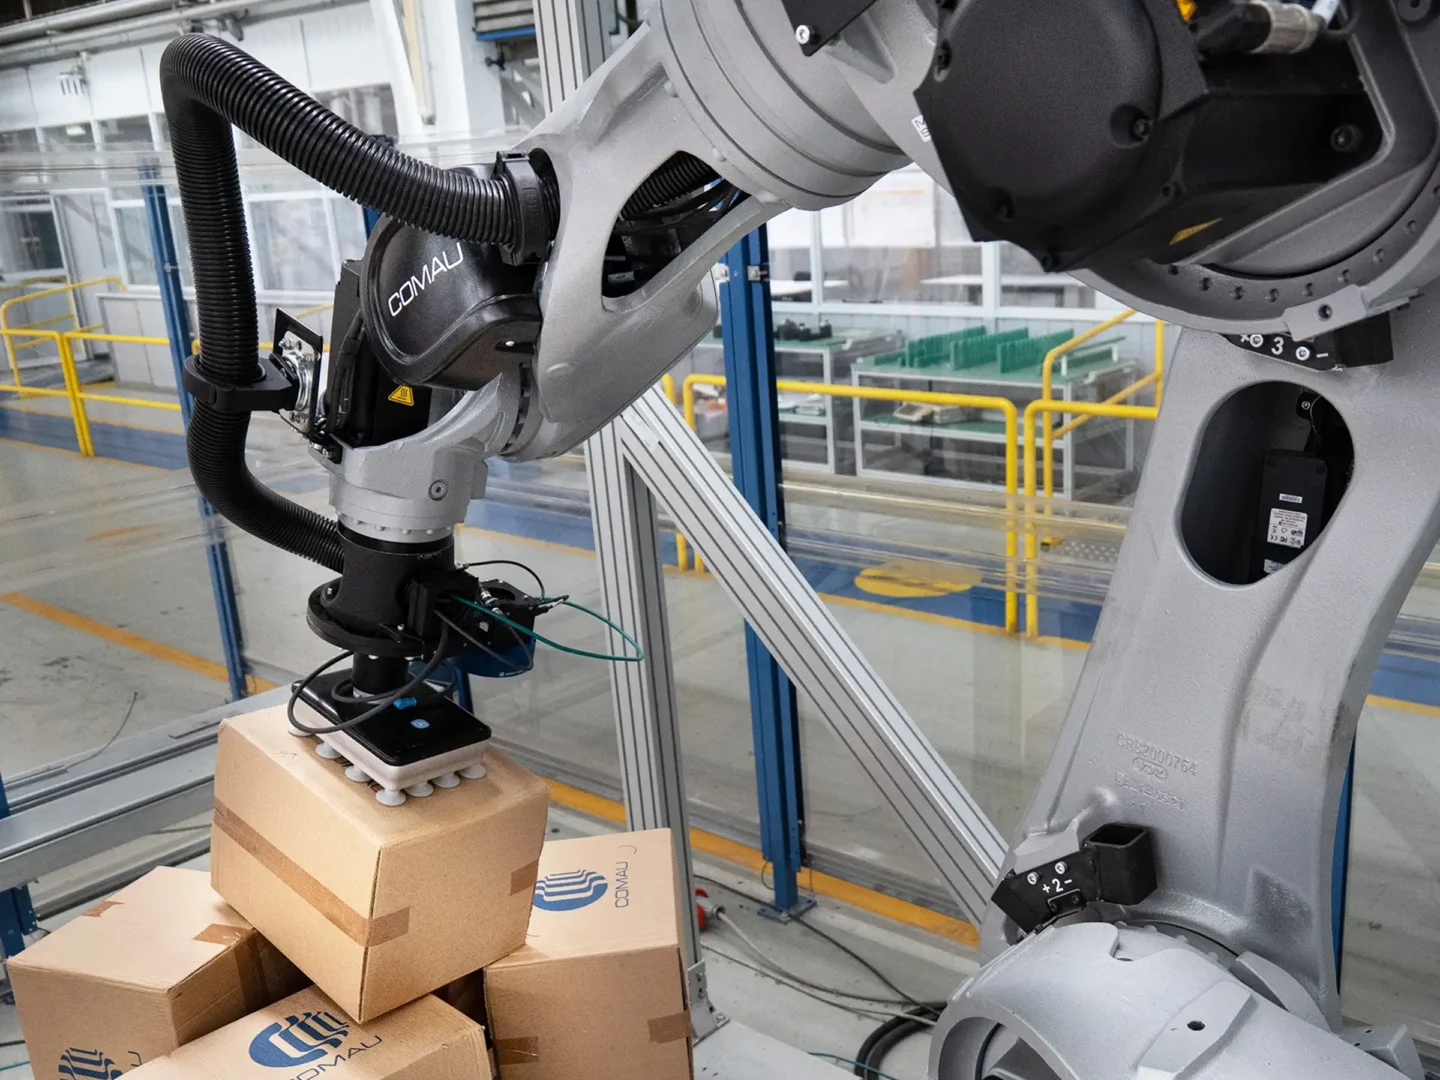
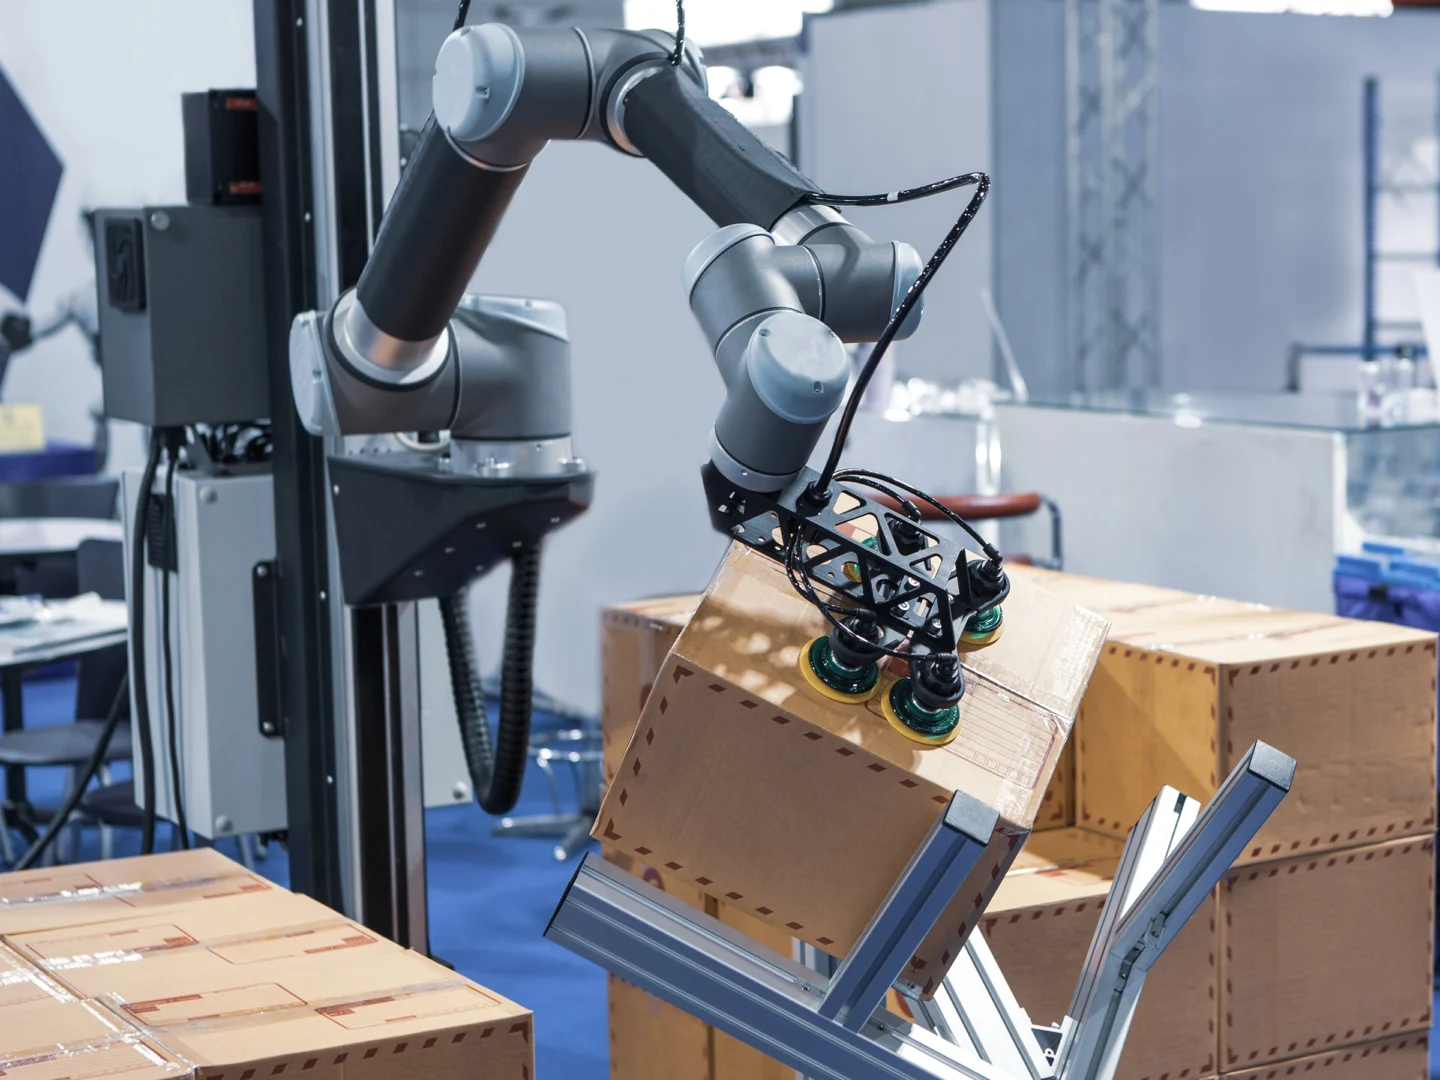
GRAIL will help robots pick and handle new or unfamiliar objects with minimal reconfiguration. By combining visual information, instructions, planning and safe mobile manipulation, the system will support more flexible logistics operations in spaces shared with human workers.
Expected impact

More flexible warehouse automation, faster adaptation to new items and safer collaboration in crowded logistics spaces.